A dancer with a prosthetic leg, arched back on a reflective floor

High-end Spatial &
Human Intelligence
For Physical AI

Powering AI with embodied spatial and human data and the behavioral-realism benchmark, from environment to behavior.

Spatial intelligence

Tens Of Thousands Of Proprietary 3D, Gaussian Splat And 360° Worlds,
From A Network Of Spatial Captures.

Warehouse
Workshop
Supermarket
Villa
Riverside walkway
Gallery
Art studio
Lobby
Room
Lounge
Glass pavilion
Kitchen
Interior
Conservatory
Garden
Timber storeroom
Equipment depot
Ceramics warehouse
Spatial intelligence

Spaces In The Physical And The Virtual World,
Captured At Scale, With Objects.

3Mhours of build data
4M+hours of play data
164Kdatapoints / hr · play + edit
Data points
3D environments
3DGS
Spatial metadata
Event streams
Physics
Hands & fingers
Joint, arm & reach
Interaction events
Behavioral layer
VLA task layer
Perception exports
Multi-agent capture
Physics-based motion
Spatial sensor (LiDAR)
Object properties
RGB
Depth
Segmentation
State
Mass
Friction
Material class
Human behavioral data

Within These Worlds, We Capture The Synthetic Human Behavior
And Real-World Human Sentiment And Expertise.

Synthetic
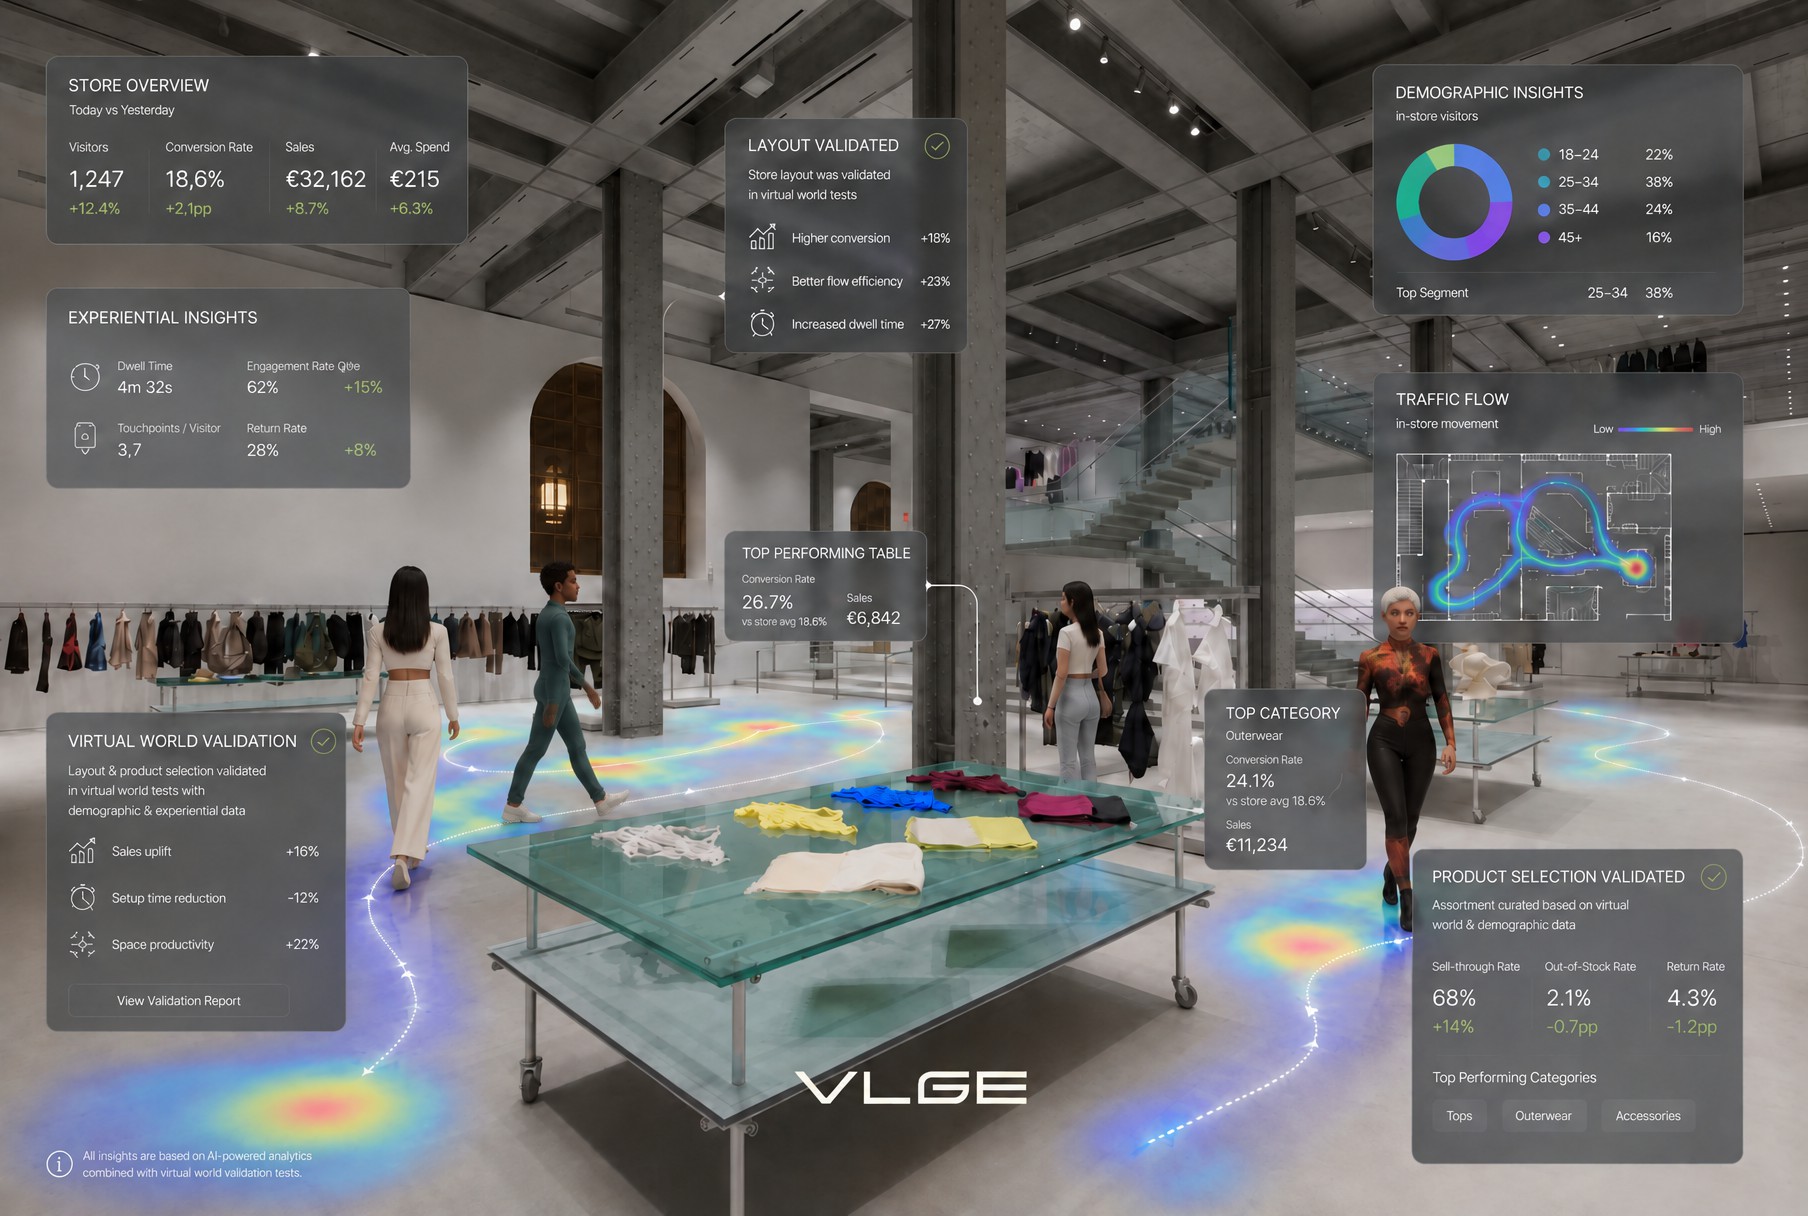
ExpertiseReal-World Human Sentiment and Expertise

Instrument the person, task and environment.

01Experts in different domains

02Skill-specific derived signals

03Transfer skills from expert to agents

ANIMATIONExperts · skill-specific signals · transfermedia/rw-strip.mp4

Shared capture schemaWhat the capture produces

VisionEgo RGB / depthWorld RGB-D / video
KinematicsBody jointsHand / finger joints
PhysiologyEMG channelsEEG channels
ContextGazeAudioObject stateTask state
415 fields in the shared schema
↓

Shared extracted features

  • Trajectory smoothness
  • Speed profile
  • Dwell time
  • Action frequency

Knife work signals

  • Blade speed
  • Cut angle
  • Grasp stability
  • Eye-before-cut
THE LANDSCAPE

With Our Synthetic And Expertise Data,
Physical AI Is Solvable.

Physical AI data forces a tradeoff: natural human behavior or reliable world state.

Ground Truth
Exact
Inferred
Agent or Operator
Natural Human
Behavior

Physics Simulation, Robot Teleop

Isaac, Habitat, PARTNR, Open-X, ALOHA

Exact state, but scripted, policy-driven, or mediated through a robot.

Generated Video

Cosmos, GR00T-Dreams

Scalable visuals, but actions and state are inferred, not ground truth

Human Ego-Video and Physiology

Ego4D, Ego-Exo4D, sEMG Band, Tesla ego rigs

Real humans, but occluded, one-shot, and disconnected from exact world state.

VLGE

Real human behavior + exact world state + repeatable as a distribution

AGENTS

Trained VLGE’s Agents On Our Real Human Behavior.

Human Build and Play
01

Human play trains the agent
run 1
run 2
run 3
run 4
run 5
run 6
×N
02

The agent scales the data

scales ×N · re-runs, keeps human-like data

HumanAgent

03

The agent generates the long tail

BENCHMARK

We Collect Real And Synthetic Human Behavior Data
To Train AI Agents, Test Their Performance On The Same Tasks,
And Prepare Them For Real-World Deployment In Robots.

We find exactly in which aspects the agent is failing, and improve it.

The Human Reference

Many people in the same scenario.
Trajectory, hesitation, decisions, attention.

The Agent

Run many times in the same scenario,
measured on the same signals.

Behavior Comparison

Compare how the agent behaves
with how people behave, signal by signal.

SUMMARY

VLGE Unlocks The Next Era Of Physical AI.

WE HAVE

Worlds3D, Gaussian splat and 360° worlds
Human Behavior in SimulationInteraction, exploration, kinematics, and manipulation
Real-World DataReal human behavior captured in the real world, e.g., tactile, sEMG, EEG, eye tracking
Digital TwinsScaling the data with synchronized annotations for movement, interactions, and world state
BenchmarkCompares human and agent behavior distributions

WE TRAIN

WORLD MODELSVideo-based, diffusion, ...
AGENTIC AIFor all AI labs
ROBOTICSVLA / Policy (e.g., OpenVLA, RT-2, ...)

The Future Of AGI Will Be
Shaped By Human Experience.